In short: Ecuhawk connects to CAN adapters through python-can, so Vector, PEAK, Kvaser, IXXAT and SocketCAN interfaces can be used. A Vector VN1630 has been tested on a real ECU bus. Bench instruments with SCPI over LAN, USB or serial are added as model files. Ecuhawk reads DBC, ARXML, FIBEX, LDF, ODX and CDD files and records BLF, ASC and MF4.
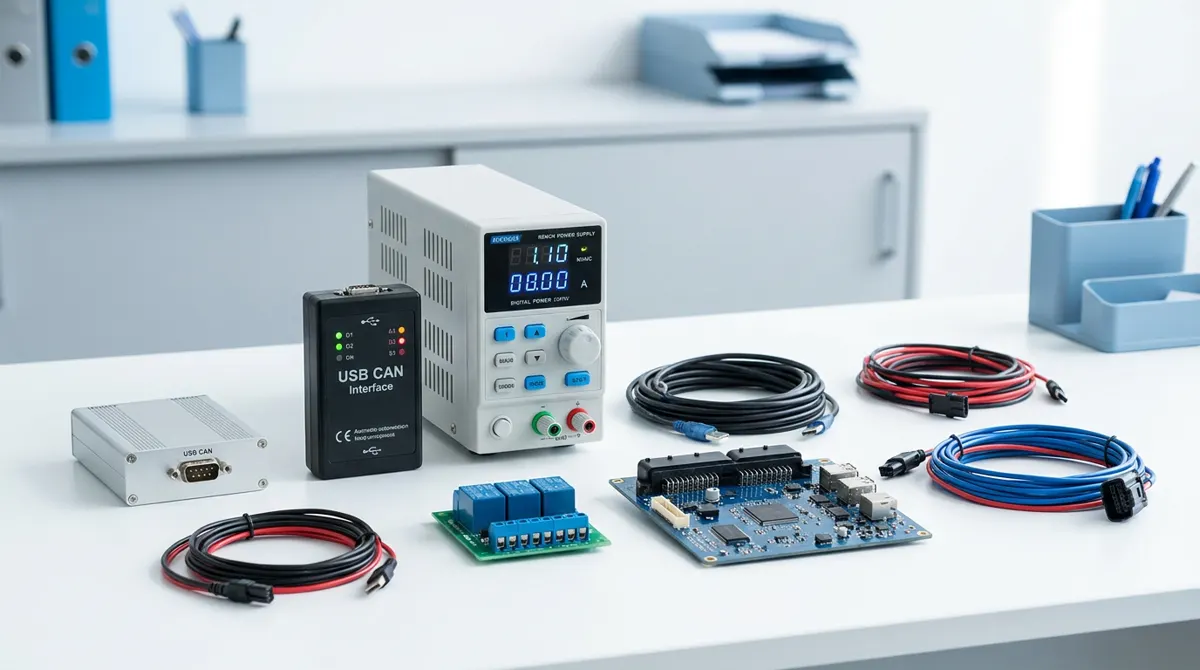
CAN adapters
| Adapter | Status |
|---|---|
| Vector (VN16xx and others, XL driver) | TESTED VN1630 receiving on a 500 kbit/s ECU bus |
| PEAK PCAN | IN BETA through python-can, being tested |
| Kvaser | IN BETA through python-can, being tested |
| IXXAT and other python-can interfaces | IN BETA through python-can |
| SocketCAN on Linux | IN BETA any adapter with a SocketCAN driver |
| Virtual bus (no hardware) | INCLUDED for simulation and training |
Buses and protocols
| Protocol | Status |
|---|---|
| CAN (11 and 29-bit) | INCLUDED |
| CAN FD | IN BETA supported in the engine, hardware testing in progress |
| UDS (ISO 14229) over ISO-TP | INCLUDED security access coming soon |
| AUTOSAR E2E, SecOC, container PDUs | INCLUDED from ARXML |
| LIN | IN BETA simulated LIN master and slaves; LIN hardware next |
| SAE J1939 | COMING SOON see J1939 testing |
| ECU flashing over UDS | COMING SOON see ECU flashing |
| XCP / CCP with A2L | COMING SOON |
| OBD-II | COMING SOON |
| DoIP, SOME/IP, Automotive Ethernet | COMING SOON |
| FlexRay | ON REQUEST |
Bench instruments
- Power supplies and electronic loads with SCPI over LAN, USB or serial. Tested: an ITECH bidirectional supply and an electronic load over LAN.
- Relays and digital I/O for KL30, KL15 and other lines.
- New brands are added as model files, not new code. AI can create a model file from the device's programming manual. See hardware integration.
File formats
| Type | Formats |
|---|---|
| Network descriptions | DBC, ARXML (AUTOSAR), FIBEX, LDF, LIN node capability files |
| Diagnostics | ODX 2.2, CDD (in beta), CSV |
| Logs | BLF, ASC, MF4 (record and open), CSV export |
| Models | FMU, DLL, Simulink-exported models |
| Tests and reports | YAML tests, HTML, PDF and JSON reports |
| Calibration | A2L COMING SOON with XCP |
Moving from CANoe
- Your DBC, ARXML, FIBEX, LDF and ODX files work as they are.
- Your BLF and ASC logs open in Ecuhawk's offline analysis.
- Vector adapters can stay on the bench.
- CANoe configurations and CAPL scripts are not imported. The usual CAPL jobs, such as rest-bus simulation and fault injection, are built in, and custom logic is written in Python. AI-assisted CAPL to Python conversion is planned.
Operating systems
Windows 10, Windows 11 and Ubuntu 24.04.
Questions
Does Ecuhawk work with Vector hardware?
Yes. Ecuhawk uses the Vector XL driver, and a Vector VN1630 has been tested on a real ECU bus.
Does Ecuhawk work with PEAK and Kvaser adapters?
Yes, through python-can. Testing with these adapters is part of the beta.
Can I use my CANoe database and log files?
Yes. DBC, ARXML, FIBEX, LDF and ODX files are read directly, and BLF and ASC logs open in offline analysis. CANoe configuration files and CAPL scripts are not imported.
Does Ecuhawk support CAN FD?
CAN FD is supported in the engine and is being tested on hardware during the beta.
Does Ecuhawk support XCP or A2L files?
Not yet. XCP and CCP calibration with A2L files is on the roadmap.